How Do Robots Communicate With PLCs (September 2026 Guide)
How Do Robots Communicate With PLCs

If you have ever walked through a modern factory and watched a robotic arm pick, place, and weld in perfect rhythm, you have seen the result of a quiet conversation. That conversation happens between the robot controller and a programmable logic controller, and it is one of the most important conversations in industrial automation. I … Read more
How Do Humanoid Robot Balance Work? (September 2026 Technical Guide)

How Do Humanoid Robots Balance

Humanoid robots balance by using a constant feedback loop: IMU sensors and force/torque sensors measure the robot’s orientation and ground contact forces, a control algorithm computes the deviation of the center of mass from the support polygon, and joint actuators adjust hundreds of times per second to keep the Zero Moment Point (ZMP) inside the … Read more

What Is MQTT Robotics and How Is It Used (September 2026)

What Is MQTT and How Is It Used in Robotics

MQTT (Message Queuing Telemetry Transport) is a lightweight, publish-subscribe messaging protocol designed for connecting IoT devices and robots over unreliable networks with minimal bandwidth. When we talk about MQTT robotics, we are talking about the de facto standard for moving data between robots, sensors, dashboards, and cloud systems. Robots need a way to talk. Whether … Read more

What Is a PLC vs Robot Controller? (September 2026)

What Is a PLC and How Does It Differ From a Robot Controller

Our team has spent the last decade integrating PLCs and robot controllers on factory floors, and the most common question we still hear from new engineers is the one driving this guide. A programmable logic controller (PLC) is a ruggedized industrial computer designed to control manufacturing processes such as assembly lines, robotic cells, and automated … Read more

How Does Robot Calibration Software Work (September 2026 Complete Guide)

How Does Robot Calibration Software Work

Robot calibration software is a specialized tool that identifies and corrects geometric errors in a robot’s kinematic model so that the machine reaches positions it was never quite hitting from the factory. In simple terms, the software measures where the robot actually goes, compares that to where its controller thinks it should go, and then … Read more

Digital Twin Robotics(September 2026 A Complete Guide)

What Is a Digital Twin in Robotics

A digital twin in robotics is a real-time virtual replica of a physical robot that stays synchronized with its sensor data, behavior, and environment. Instead of guessing how a robot will perform, engineers can run experiments, train AI models, and catch failures inside a simulator that mirrors the real machine down to the last joint … Read more

A* vs RRT Path Planning Explained (September 2026)

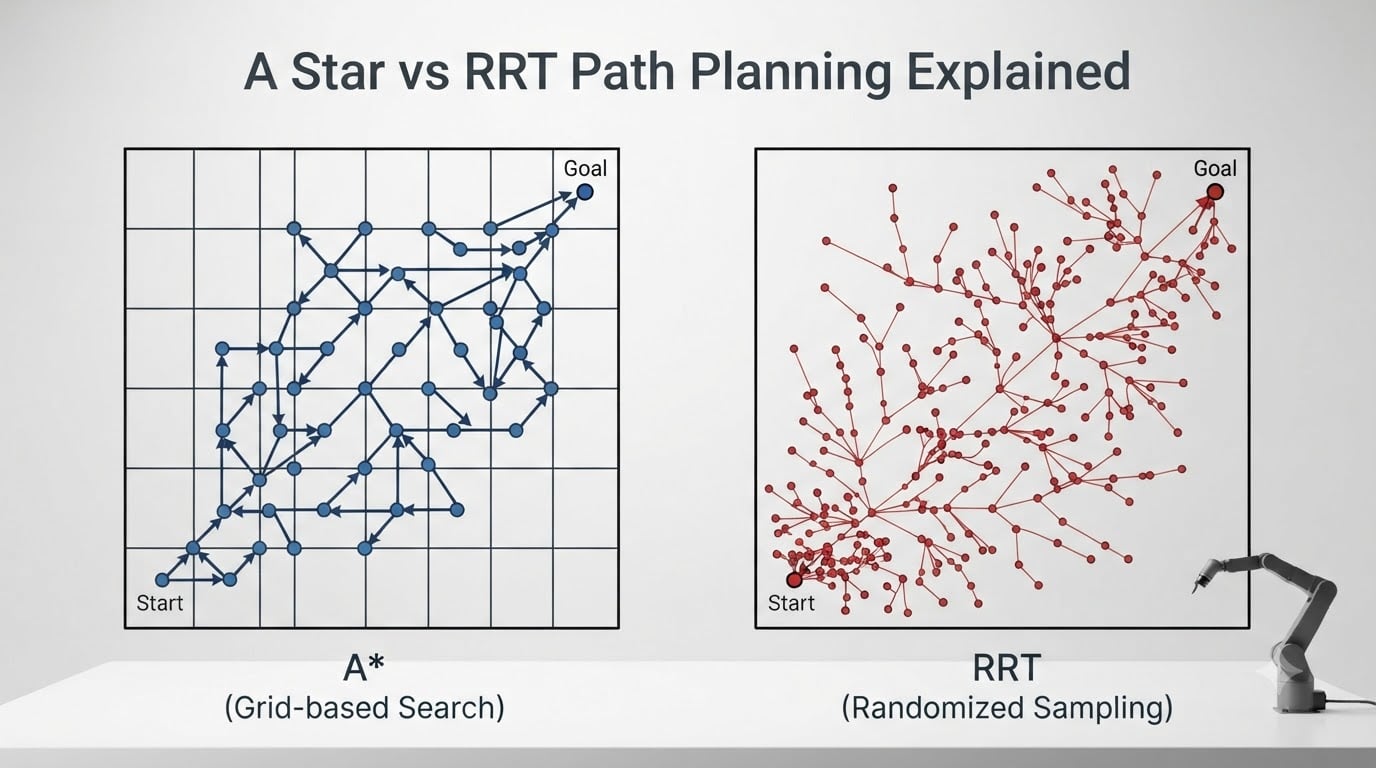
A Star vs RRT Path Planning Explained

If you’ve ever wondered how a robot decides where to move, you’ve landed in the right place. Path planning is the brain behind every autonomous system, and two algorithms dominate the conversation: A* (A-Star) and RRT (Rapidly-exploring Random Tree). I work with both regularly in robotics projects, and each one has clear strengths, clear weaknesses, … Read more