URDF File Robotics: What Is a URDF File in Robotics?(September 2026 Guide)
What Is a URDF File in Robotics

A URDF (Unified Robot Description Format) file is an XML-based file used in robotics to describe a robot’s physical structure, including its links, joints, and visual and collision properties. It provides a standardized way to represent multibody systems so that tools like ROS, Gazebo, and RViz can share and understand robot models without custom conversion. … Read more
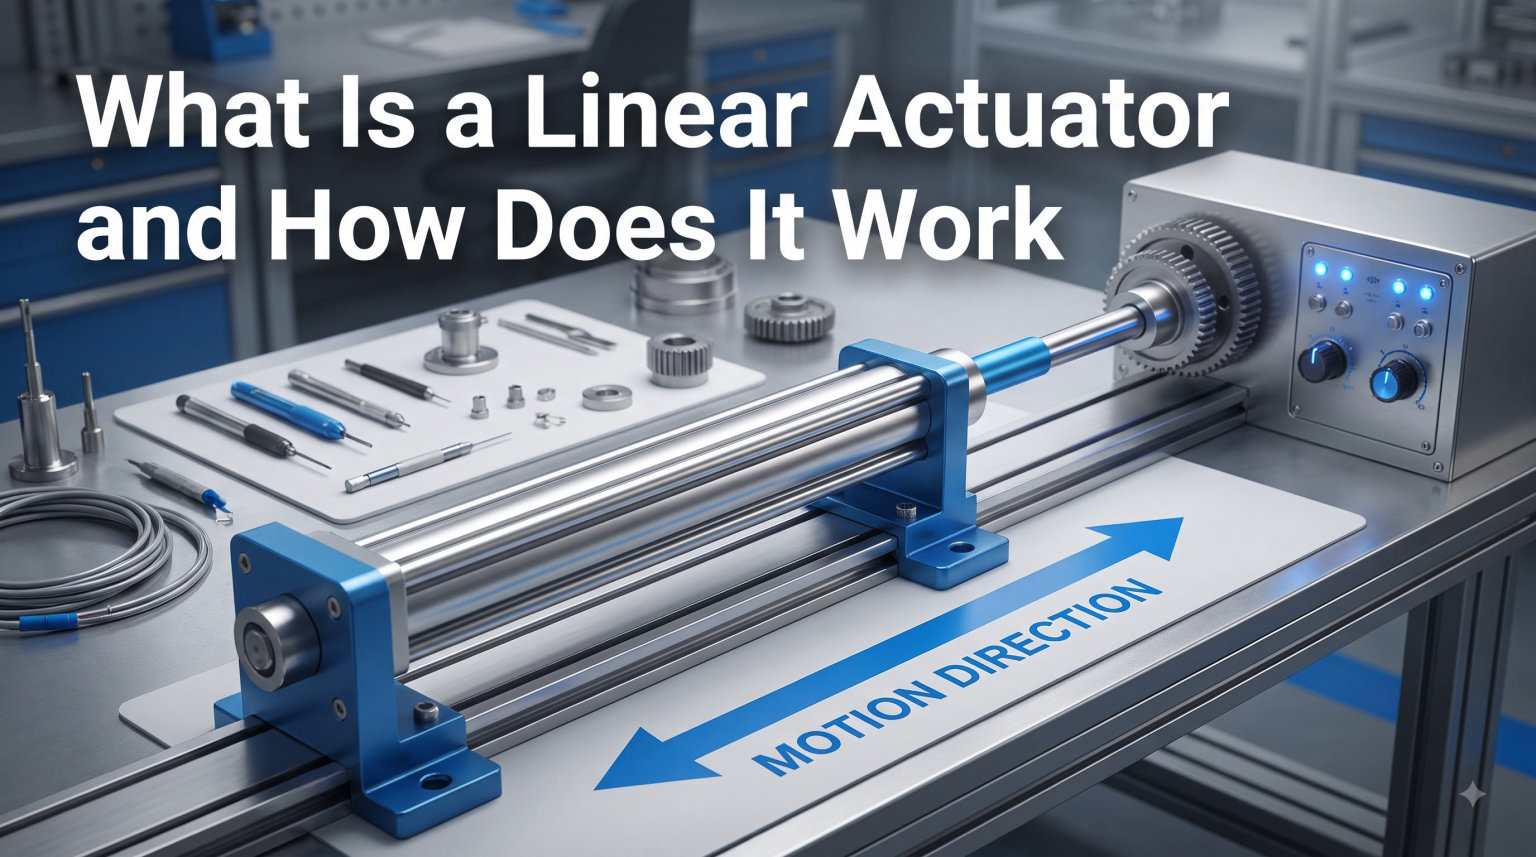
What Is a Linear Actuator and How Does It Work Guide (September 2026)

What Is a Linear Actuator and How Does It Work

A linear actuator is a mechanical device that converts rotational motion from a motor into straight-line push or pull movement. In simple terms, it spins something inside so that something else on the outside moves in a straight line, and that one trick is the reason factories, robot arms, hospital beds, and even DIY camera … Read more

How Do Infrared Sensors Work in Robots (September 2026 Full Guide)

How Do Infrared Sensors Work in Robots

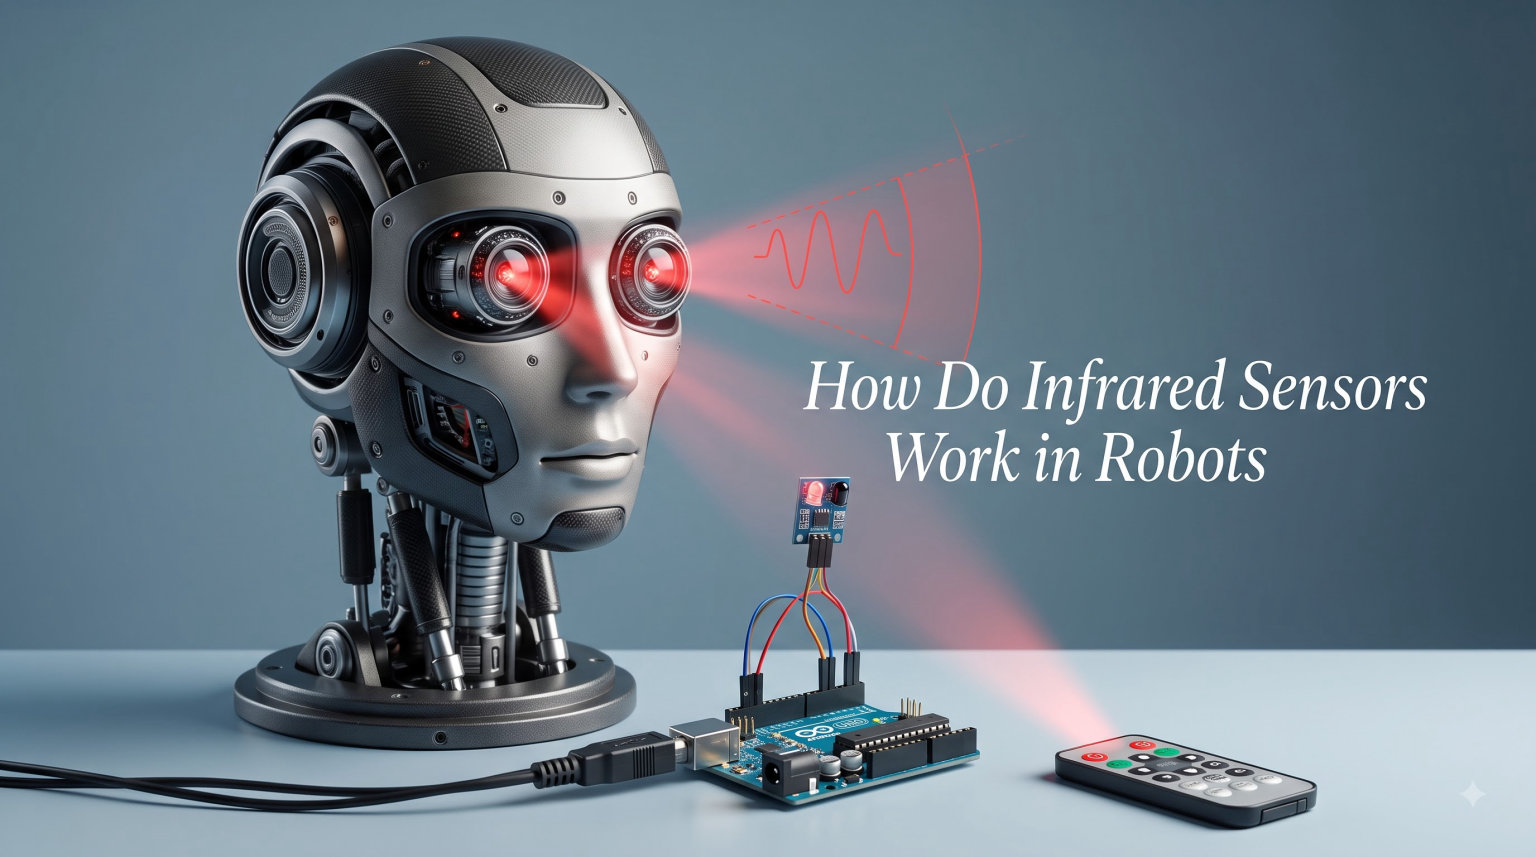
Infrared (IR) sensors are the workhorses behind robot obstacle detection, line following, and distance measurement. In our robotics builds, they have been the cheapest, fastest way to give a machine a sense of touch at a distance, which is exactly why the question how do infrared sensors work in robots comes up so often in … Read more

Robot Vacuum Cliff Detection (September 2026 How It Works)

How Do Robot Vacuums Detect Cliffs and Stairs

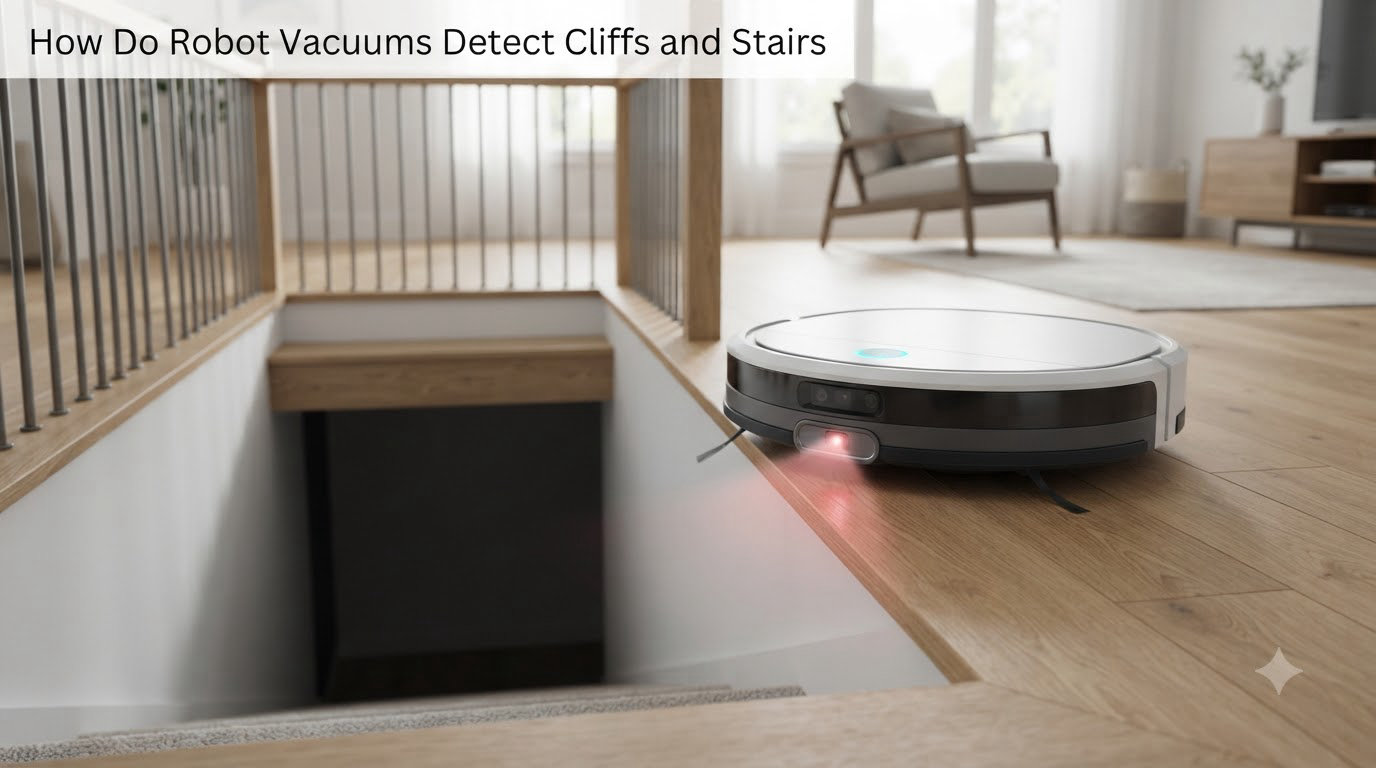
Most robot vacuums detect cliffs and stairs using small infrared cliff sensors mounted on the underside of the chassis. These sensors shine an invisible infrared beam toward the floor, and when the floor suddenly disappears (like the edge of a stair step), the beam fails to bounce back. That missing reflection tells the vacuum’s brain … Read more

What Is a Complementary Filter IMU Guide (September 2026 Complete Overview)

What Is a Complementary Filter for IMU Data

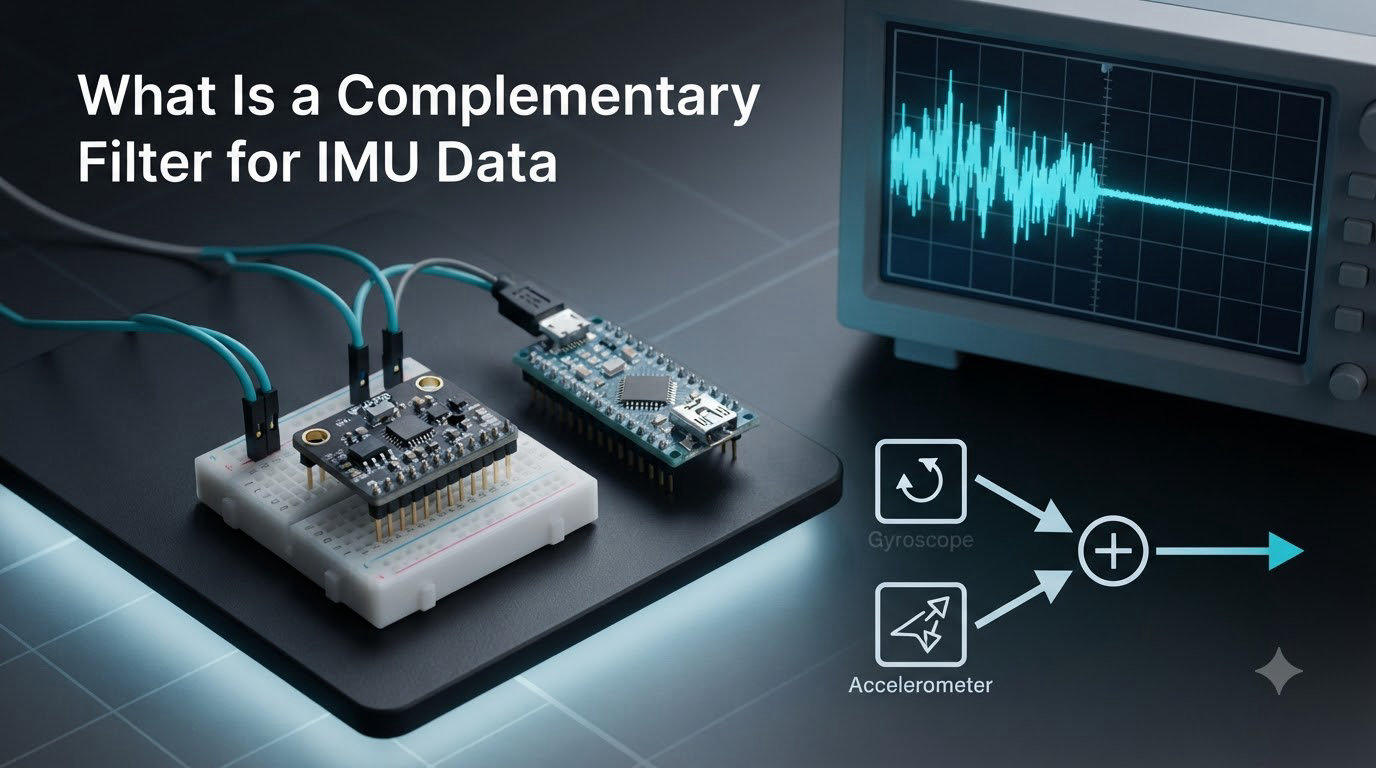
A complementary filter is a sensor fusion method that combines gyroscope and accelerometer data to estimate orientation in an IMU, using a high-pass filter on the gyro and a low-pass filter on the accelerometer to cancel out each sensor’s weaknesses. In this guide I will walk you through how it works, the actual formula, and … Read more

Sensor Noise Filtering (September 2026 Causes and Solutions)

What Causes Sensor Noise and How to Filter It

If your robot’s IMU drifts, your force-torque readings jitter, or your temperature sensor outputs look like a seismograph during a small earthquake, you are dealing with sensor noise. I have spent more time than I would like to admit debugging these exact issues across robotic arms, mobile platforms, and embedded sensor stacks. After testing dozens … Read more

How Do Current Sensors Protect Robot Motors? (September 2026)

How Do Current Sensors Protect Robot Motors

A current sensor is an electronic device that measures the electrical current flowing through a motor or circuit, then converts that measurement into a signal a controller can read and act on. In robotics, current sensors protect robot motors by detecting overcurrent, overload, stall, and thermal fault conditions in real time, allowing the controller to … Read more