How Do Stepper Motors Work (September 2026 A Complete Beginner’s Guide)
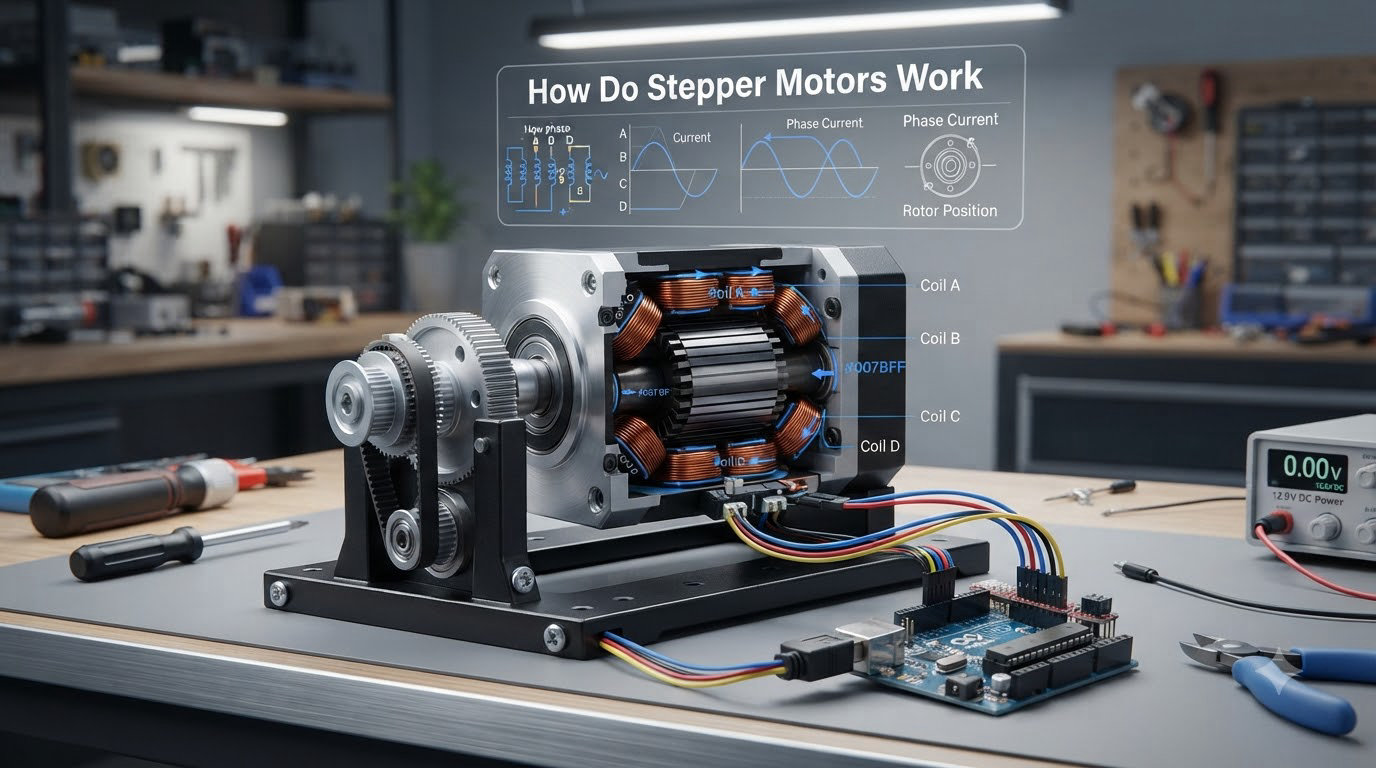
How Do Stepper Motors Work

I’ve spent years working with motors in robotics projects, and stepper motors remain one of the most fascinating devices in any maker’s toolbox. The short answer to how do stepper motors work: they convert electrical pulses into precise, fixed angular steps, allowing exact positioning without needing feedback sensors. That single capability is why you’ll find … Read more
How Do Proximity Sensors Work (September 2026 Complete Guide)

How Do Proximity Sensors Work

A proximity sensor is a non-contact device that detects nearby objects by emitting an electromagnetic field, a beam of electromagnetic radiation (such as infrared), or sound waves, then measuring changes in the return signal. When a target object enters the detection zone, the sensor registers a change and triggers an ON or OFF switch signal. … Read more

What Is an Ultra Wideband Positioning System (September 2026)

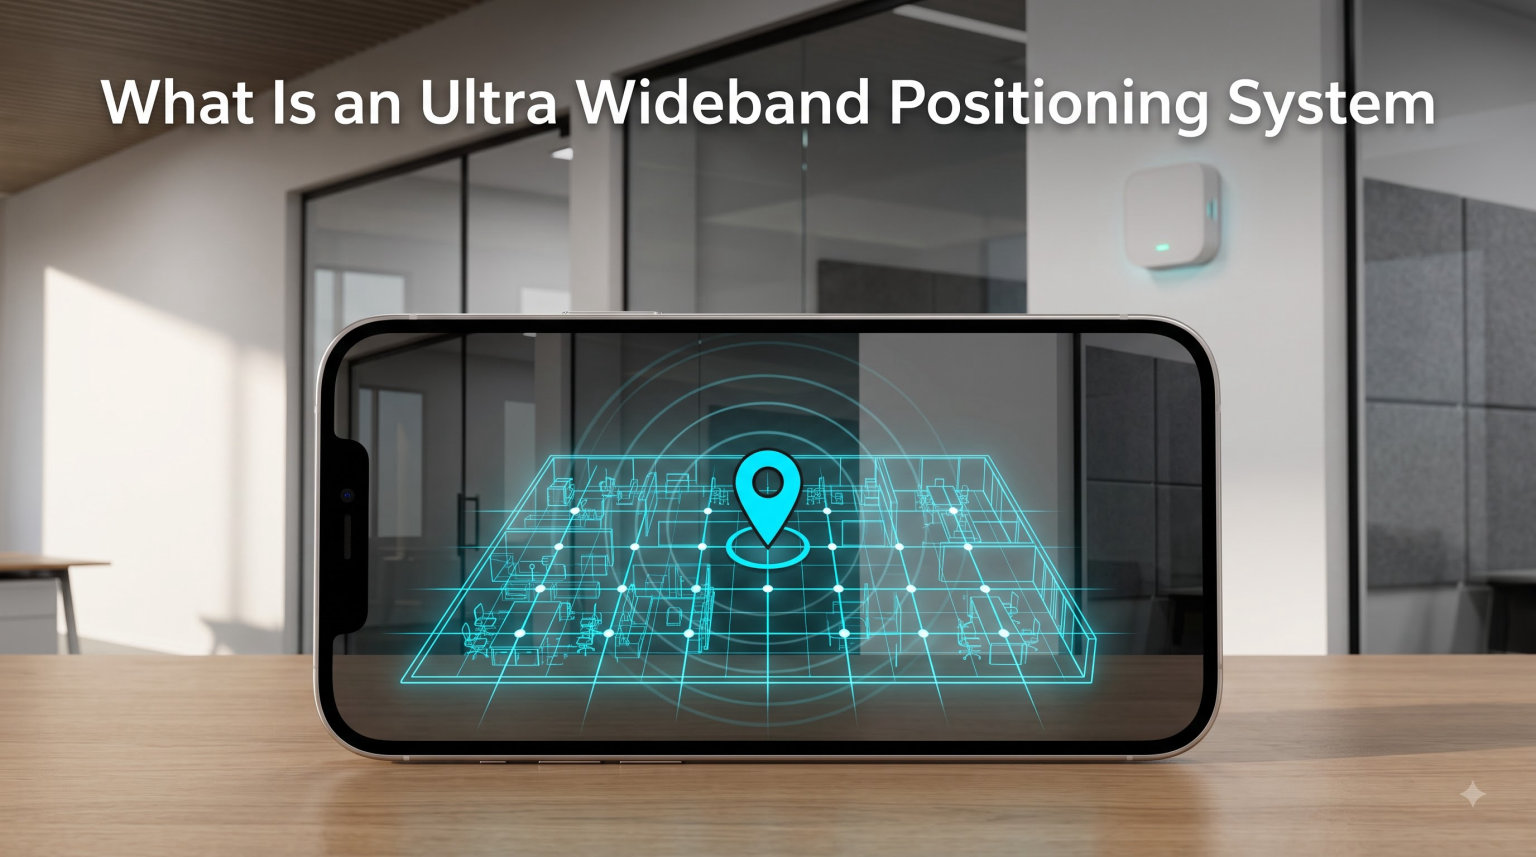
What Is an Ultra Wideband Positioning System

An ultra wideband positioning system is a short-range radio technology that achieves 10cm indoor accuracy by sending precisely timed pulses across a very wide frequency spectrum. Unlike WiFi or Bluetooth, it measures how long those pulses take to travel between devices, which is why it powers everything from warehouse tracking to Apple’s AirTags. In this … Read more

How Do Robots Sense Temperature? (September 2026 Complete Guide)

How Do Robots Sense Temperature

Robots sense temperature through specialized sensors that convert thermal energy into electrical signals a microcontroller can read. I have spent the last several years testing these sensors across hobby projects, industrial prototypes, and research platforms, and the four core families you will encounter are thermocouples, thermistors, resistance temperature detectors (RTDs), and infrared sensors. Each one … Read more

Why GPS Indoor Robots Fail (September 2026 Expert Guide)

Why GPS Does Not Work Indoors for Robots

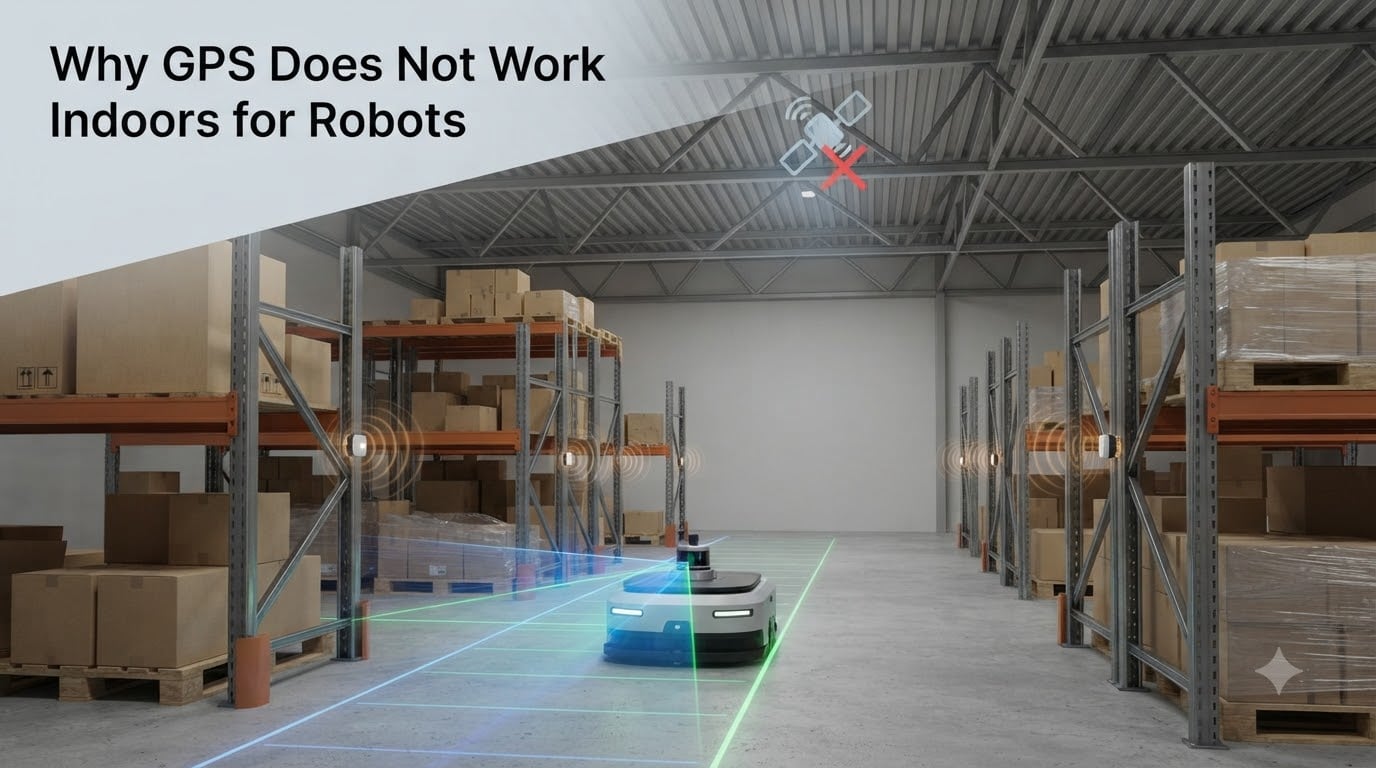
GPS does not work indoors for robots because the satellite signals are intentionally weak (around -130 dBm at the Earth’s surface) and cannot penetrate building materials like concrete, metal, and brick. I have spent years testing autonomous platforms in warehouses, and every time a robot rolls under a steel roof, the position fix either drops … Read more

Dead Reckoning in Robot Navigation (September 2026 Complete Guide)

What Is Dead Reckoning in Robot Navigation

Dead reckoning in robot navigation is the process of estimating a robot’s current position by starting from a known location and adding up how far and in what direction the robot has moved since. The name comes from the old航海 phrase deduced reckoning, and the technique has been used by sailors, pilots, and now robots … Read more

How Do Robotic Arms Achieve Precision (September 2026 Complete Guide)

How Do Robotic Arms Achieve Precision

When I first watched a six-axis arm place a microchip onto a circuit board without touching the surrounding components, I had to ask the same question most engineers eventually ask: how do robotic arms achieve precision at that level? The answer is not one clever trick. It is a stack of mechanical, electronic, and software … Read more

Stereo Vision vs Structured Light (September 2026 Tech Guide)

Stereo Vision vs Structured Light Depth Sensing

When our team started building 3D perception into our first autonomous mobile robot in 2019, we picked stereo vision because it looked cheaper on the bill of materials. Three months later we were stuck on a warehouse floor where the boxes were uniform brown and the lighting flickered between LED and sodium. Depth output looked … Read more